
Aging creep: loading age against inclusion shape
The whole page as one script
Every block of this page, in order, is scripts/87_aging_ages_aspect.jl. From a clone of the repository, julia --project=docs -e 'using Pkg; Pkg.instantiate()' once, then julia scripts/87_aging_ages_aspect.jl, runs it end to end.
Before this page
The tutorial Aging viscoelastic schemes side by side, which reads a uniaxial creep test off the Volterra matrix as done below, and the theory page Aging linear Volterra behavior (ALV), where the aging creep function
An aging viscoelastic material is one whose creep compliance
This page runs one composite — a viscoelastic matrix with viscoelastic inclusions, 20 % by volume, homogenized by Mori-Tanaka — and sweeps the two parameters that fight each other:
the loading age
the inclusion aspect ratio
Both act on the same output, the effective uniaxial creep function
using MeanFieldHomogenization
using TensND
using LinearAlgebra
using Printf
using Plots
gr()

include(joinpath(pkgdir(MeanFieldHomogenization), "scripts", "common", "docviz.jl"))
_flattening (generic function with 1 method)The microstructure
Spheroidal inclusions at 20 %, all aligned. Flattening them from
plotly_scene(
    rve_traces(;
        n = 60, semi_axes = (0.085, 0.085, 0.028), seed = 1949,
        orientation = (0.0, 0.0, 1.0)
    );
    uid = "aa-rve", height = 470,
    title = "Aligned oblate inclusions, ω = 1/3 (drawn thicker than the run for legibility)"
)
Two aging creep laws
Each phase creeps in two additive parts: a relaxing elastic term whose amplitude decays with the loading age TensISO{3}(a, b) with
# Matrix: E = 1, ν = 0.2.
const Es, νs = 1.0, 0.2
const ks, μs = k_mu(iso_stiffness_E_nu(Es, νs))
fk_s(tp) = 0.5 * exp(-tp / 20) + 0.5
fμ_s(tp) = 0.5 * exp(-tp / 20) + 0.5

function J_matrix(t, tp)
    a = fk_s(tp) / (3ks) + 1.0e-1 / ks * log(1 + (t - tp) / 2)
    b = fμ_s(tp) / (2μs) + 1.0e-1 / μs * log(1 + (t - tp) / 1)
    return TensISO{3}(a, b)
end

# Inclusions: stiffer and less compliant, E = 3, ν = 0.3, aging faster.
const Ei, νi = 3.0, 0.3
const ki, μi = k_mu(iso_stiffness_E_nu(Ei, νi))
fk_i(tp) = 0.3 * exp(-tp / 10) + 0.4
fμ_i(tp) = 0.4 * exp(-tp / 15) + 0.3

function J_inclusion(t, tp)
    a = fk_i(tp) / (3ki) + 1.0e-1 / ki * log(1 + (t - tp) / 2)
    b = fμ_i(tp) / (2μi) + 1.0e-1 / μi * log(1 + (t - tp) / 1)
    return TensISO{3}(a, b)
end

const law_s = ViscoLaw(J_matrix, :creep)
const law_i = ViscoLaw(J_inclusion, :creep)

@printf "matrix    : k = %.4f  μ = %.4f\n" ks μs
@printf "inclusion : k = %.4f  μ = %.4f\n" ki μi
matrix : k = 0.5556 μ = 0.4167
inclusion : k = 2.5000 μ = 1.1538The time grid
A creep test loaded at
The grid is deliberately short (30 + 30 points): the ALV pipeline assembles and inverts a
function creep_times(tp; n1 = 30, n2 = 30, tmax = 50.0)
    t0 = tp == 0 ? 1.0e-4 : float(tp)
    first_decade = exp10.(range(log10(t0), log10(t0 + 1); length = n1 + 1))[1:(end - 1)]
    tail = exp10.(range(log10(t0 + 1), log10(tmax); length = n2))
    return vcat(first_decade, tail)
end
creep_times (generic function with 1 method)Uniaxial creep from the effective relaxation matrix
homogenize_alv returns the effective relaxation block matrix. Inverting it in the Volterra sense gives the creep matrix, and applying a unit uniaxial stress step at the first time of the grid gives the axial strain history — which is
function uniaxial_creep(R_eff, n)
    J_eff = volterra_inverse(R_eff; block_size = 6)
    Σ = zeros(6n)
    for i in 1:n
        Σ[6 * (i - 1) + 1] = 1.0            # unit axial stress, held constant
    end
    return (J_eff * Σ)[1:6:end]
end

function creep_composite(f, ω, times)
    r = RVE()
    add_phase!(r, :M, Spheroid(1.0), Dict(:C => law_s); fraction = :rest)
    add_phase!(r, :I, Spheroid(ω), Dict(:C => law_i); fraction = f)
    R = homogenize_alv(r, MoriTanaka(), :C; times = times)
    return uniaxial_creep(R, length(times))
end

# A single phase on its own needs no scheme: its own Volterra matrix is the
# answer, and going through an RVE of fraction 0 or 1 would only add a
# degenerate matrix phase.
function creep_single(law, times)
    J = trapezoidal_matrix(law, times)
    R = volterra_inverse(J; block_size = 6)
    return uniaxial_creep(R, length(times))
end
creep_single (generic function with 1 method)The sweep
Three loading ages, three aspect ratios, plus the two pure phases as bounds.
const AGES = (0.0, 20.0, 40.0)
const OMEGAS = (1.0, 0.1, 0.01)
const F_INC = 0.2

results = Dict{Tuple{Float64, Any}, Tuple{Vector{Float64}, Vector{Float64}}}()
for tp in AGES
    times = creep_times(tp)
    results[(tp, :matrix)] = (times, Es .* creep_single(law_s, times))
    results[(tp, :inclusion)] = (times, Es .* creep_single(law_i, times))
    for ω in OMEGAS
        results[(tp, ω)] = (times, Es .* creep_composite(F_INC, ω, times))
    end
end

@printf "%-6s %-10s %10s %10s\n" "t'" "phase/ω" "J·E at t'+1" "J·E at 50"
for tp in AGES, key in (:matrix, OMEGAS..., :inclusion)
    t, J = results[(tp, key)]
    i1 = findfirst(≥(t[1] + 1 - 1.0e-9), t)
    @printf "%-6.0f %-10s %10.4f %10.4f\n" tp string(key) J[i1] J[end]
end
t' phase/ω J·E at t'+1 J·E at 50
0 matrix 1.1352 1.8246
0 1.0 0.8896 1.4507
0 0.1 0.7702 1.2847
0 0.01 0.7108 1.2065
0 inclusion 0.2788 0.5039
20 matrix 0.8192 1.3997
20 1.0 0.6341 1.1073
20 0.1 0.5385 0.9735
20 0.01 0.4892 0.9095
20 inclusion 0.1822 0.3721
40 matrix 0.7029 1.0588
40 1.0 0.5450 0.8356
40 0.1 0.4641 0.7318
40 0.01 0.4226 0.6816
40 inclusion 0.1582 0.2752The table already shows the two effects separately. Reading down the blocks is aging: the same microstructure loaded later creeps less. Reading across the three
The figure
One panel per loading age, so the aging is the shift between panels and the shape effect is the spread inside each.
const COLORS = Dict(1.0 => :magenta, 0.1 => :red, 0.01 => :green)

panels = map(AGES) do tp
    p = plot(;
        xscale = :log10, xlabel = "t", ylabel = "E_mat · J_E^hom(t, t′)",
        title = "loading age t′ = $(Int(tp))", titlefontsize = 10,
        framestyle = :box, legend = (tp == AGES[1] ? :topleft : false),
        ylims = (0.0, 3.2)
    )
    t, J = results[(tp, :matrix)]
    plot!(p, t, J; lw = 2, color = :black, label = "matrix alone")
    t, J = results[(tp, :inclusion)]
    plot!(p, t, J; lw = 2, color = :blue, label = "inclusion alone")
    for ω in OMEGAS
        t, J = results[(tp, ω)]
        plot!(p, t, J; lw = 2, color = COLORS[ω], label = "f = $F_INC, ω = $ω")
    end
    p
end

p_all = plot(
    panels...; layout = (1, 3), size = (1080, 440),
    left_margin = 8Plots.mm, bottom_margin = 8Plots.mm, titlefontsize = 9
)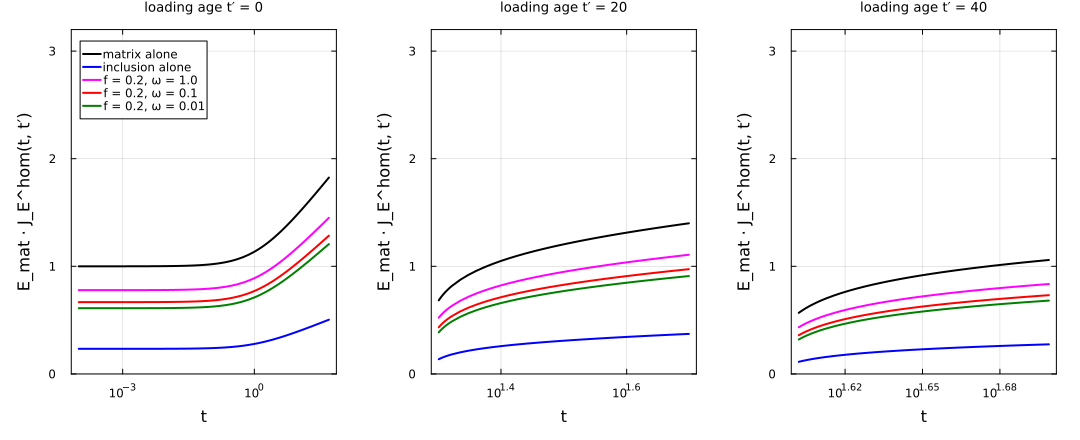
Three things are worth naming in that figure.
The composite is bracketed by its phases, at every time and every age. That is not automatic for an aging problem — the bound holds here because both phases share the same kind of kernel.
Aging shifts the whole family down. Between
The aspect ratio orders the curves the same way at every age. Morphology and aging do not interact here: the shape effect is a near-constant offset, which is exactly the property that makes it legitimate to calibrate a microstructure on one loading age and reuse it at another.
The shape effect, isolated
Dividing by the spherical case removes the aging and leaves the morphology.
p_ratio = plot(;
    xscale = :log10, xlabel = "t − t′ + 1", ylabel = "J_E^hom(ω) / J_E^hom(ω = 1)",
    framestyle = :box, legend = :topleft, size = (760, 460),
    title = "Shape effect on the effective creep, f = $F_INC"
)
for tp in AGES, ω in (0.1, 0.01)
    t, J = results[(tp, ω)]
    _, J1 = results[(tp, 1.0)]
    plot!(
        p_ratio, t .- t[1] .+ 1, J ./ J1;
        lw = 2, color = COLORS[ω], ls = (tp == 0.0 ? :solid : tp == 20.0 ? :dash : :dot),
        label = "ω = $ω, t′ = $(Int(tp))"
    )
end
p_ratio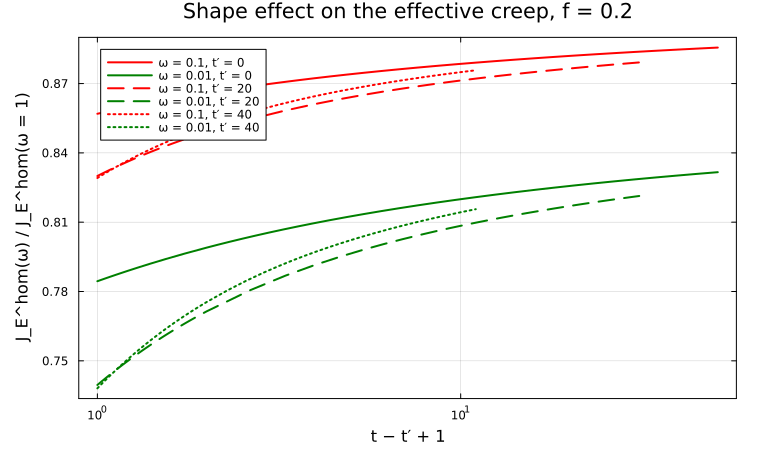
The three line styles are the three loading ages, and they nearly coincide: the ratio depends on
for ω in (0.1, 0.01)
    line = String[]
    for tp in AGES
        _, J = results[(tp, ω)]
        _, J1 = results[(tp, 1.0)]
        push!(line, @sprintf("t′=%2.0f : %.4f", tp, J[end] / J1[end]))
    end
    @printf "ω = %-5s  %s\n" ω join(line, "   ")
end
ω = 0.1 t′= 0 : 0.8856 t′=20 : 0.8791 t′=40 : 0.8757
ω = 0.01 t′= 0 : 0.8316 t′=20 : 0.8213 t′=40 : 0.8156Along each printed line, the ratio barely moves from one loading age to the next.
Where to go next
The two parameters above are swept on a coarse grid, whereas the response to a small change of a parameter is better obtained as a derivative. Derivatives through the aging-viscoelastic pipeline differentiates such outputs with ForwardDiff, with respect to a volume fraction, a modulus or a relaxation time, through the whole Volterra assembly.
Aging viscoelastic schemes side by side — the same kind of test across Dilute / Mori-Tanaka / Maxwell / PCW
Frequency or time? — when the non-aging frequency route is enough
Aging creep of solidifying cementitious materials — an aging model where the phase fractions also evolve
The viscoelasticity manual — every ALV entry point
This page was generated using Literate.jl.