
Quasi-brittle strength of cement paste and mortar
Before this page
The tutorial From derivatives to a strength criterion, where a strength criterion is obtained from the derivative of the effective moduli with respect to a phase modulus, Multiscale models for the chaining of the three scales, and Sensitivities — autodiff via ForwardDiff for the dual numbers propagated through that chain.
This chapter implements the multi-scale strength-upscaling model of (Pichler and Hellmich, 2011) — and mirrors the corresponding chapter of the Echoes book (Barthélémy, 2026). It predicts the macroscopic uniaxial compressive strength
| Scale | RVE | Phases | Scheme |
|---|---|---|---|
| 1 | Hydrate foam (HF) | oriented hydrate needles + water + air | Self-Consistent |
| 2 | Cement paste (CP) | HF matrix + clinker grains | Mori-Tanaka |
| 3 | Mortar (MO) | CP matrix + sand grains | Mori-Tanaka |
The criterion needs Dual, read the partial of the final C_mo. Both routes agree to the tolerances of Cross-validation.
The code below is the model of scripts/common/quasibrittle_strength.jl, reproduced inline.
Constants and volume fractions
Densities (relative to water) and phase moduli are those of (Pichler and Hellmich, 2011). Powers' hydration model gives the volume fractions of clinker, water, hydrates and air as functions of
using MeanFieldHomogenization
using TensND
using ForwardDiff
using LinearAlgebra
using Plots
gr()  # headless backend; GKSwstype is set to "100" in make.jl

const d_clin, d_hyd, d_san = 3.15, 2.073, 2.648
const K_clin, μ_clin = 116.7, 53.8
const K_hyd_ref, μ_hyd_ref = 18.7, 11.8
const K_san, μ_san = 37.8, 44.3

# Water/air are regularized to a tiny positive stiffness: it selects the
# percolating SC branch and keeps the iteration smooth (deliberate deviation
# from the exact zero of Echoes, and the source of the gap with it: 1 to 3 % on
# f_c at the lowest hydration degrees, below 0.5 % beyond).
const TINY = 1.0e-3
const NTHETA = 20
const ω_aspect = 1.0e4

f_clin(wc, α) = (1 - α) / (1 + d_clin * wc)
f_w(wc, α) = d_clin * (wc - 0.42α) / (1 + d_clin * wc)
f_hyd(wc, α) = 1.42 * d_clin / d_hyd * α / (1 + d_clin * wc)
fh_san(wc, sc) = sc / d_san / (1 / d_clin + wc + sc / d_san)
αmax(wc) = min(1.0, wc / 0.42)
Scale 1 — hydrate foam (multi-bin self-consistent)
The hydrate crystals are near-perfect needles (prolate spheroids, NTHETA polar bins (polar_orientation_bins); each bin is one Spheroid family tilted by its polar angle and carrying a TISymmetrize — the exact azimuthal average about the global axis μ_b0 so it can later be seeded with a ForwardDiff.Dual.
The self-consistent iteration of these families needs a starting point, and two are offered, which reach the same fixed point.
Two stages: an isotropic estimate, then the discrete families
With start = :iso, the default, the foam is first solved with a single needle family averaged over every orientation (symmetrize = :iso). Its reference medium stays isotropic, so every Hill tensor of that iteration is a closed form, and the whole stage costs a fraction of a millisecond. The discrete families start from that estimate, which their own fixed point differs from by the discretization alone: a few iterations remain, each of which evaluates the Hill tensors of twenty tilted needles in a transversely isotropic medium by quadrature. This is the route of the Echoes chapter.
One stage: the discrete families from the hydrate stiffness
With start = :direct, the discrete families start from the stiffness of the hydrates. The iteration is longer, and its early iterates are far from isotropic, which makes their quadratures more expensive; it is kept to check the first route, as the section Validating the angular discretization does.
foam_fractions(wc, α_p) = (fclin = f_clin(wc, α_p); fw = f_w(wc, α_p); fhyd = f_hyd(wc, α_p);
    fair = max(0.0, 1 - fclin - fw - fhyd); (fhyd, fw, fair) ./ (1 - fclin))
const SC_TOL = (; abstol = 1.0e-8)

# Stage 1: one isotropically averaged needle family, a closed form at every iteration.
function build_hf_iso(wc, α_p; ω = ω_aspect, sc_tol = SC_TOL)
    fthyd, ftw, ftair = foam_fractions(wc, α_p)
    C_hyd = TensISO{3}(3K_hyd_ref, 2μ_hyd_ref)
    rve = RVE()
    add_phase!(rve, :CP, Ellipsoid(1.0), Dict(:C => C_hyd); fraction = :rest)
    add_phase!(rve, :HYD, Spheroid(ω), Dict(:C => C_hyd); fraction = fthyd, symmetrize = :iso)
    C_tiny = TensISO{3}(3TINY, 2TINY)
    add_phase!(rve, :W, Ellipsoid(1.0), Dict(:C => C_tiny); fraction = ftw)
    add_phase!(rve, :AIR, Ellipsoid(1.0), Dict(:C => C_tiny); fraction = ftair)
    return homogenize(rve, SelfConsistent(; sc_tol..., maxiters = 1000), :C; select_best = true)
end

# The starting point of the discrete families, in the element type T of the chain.
_hf_init(::Val{:iso}, wc, α_p, ω, sc_tol, ::Type{T}) where {T} =
    TensISO{3}(map(x -> convert(T, x), TensND.get_data(build_hf_iso(wc, α_p; ω, sc_tol)))...)
_hf_init(::Val{:direct}, wc, α_p, ω, sc_tol, ::Type) = nothing

function build_hf(wc, α_p, μ_b0; N = NTHETA, ω = ω_aspect, start = :iso, sc_tol = SC_TOL)
    fthyd, ftw, ftair = foam_fractions(wc, α_p)
    T = typeof(μ_b0)
    ez = (0.0, 0.0, 1.0)
    rve = RVE(; T = T)
    # Zero-volume matrix = SC seed only (Σ inclusion fractions = 1). The spheres
    # (seed, water, air) are not averaged: an isotropic sphere contributes with
    # the symmetry of the reference already, transversely isotropic about e₃.
    add_phase!(rve, :CP, Ellipsoid(1.0), Dict(:C => TensISO{3}(convert(T, 3K_hyd_ref), convert(T, 2μ_hyd_ref))); fraction = :rest)
    for (i, bin) in enumerate(polar_orientation_bins(N))
        μ_h = i == 1 ? μ_b0 : convert(T, μ_hyd_ref)
        add_phase!(
            rve, Symbol(:HYD, i),
            Spheroid(ω; euler_angles = (bin.θ, 0.0, 0.0)),
            Dict(:C => TensISO{3}(convert(T, 3K_hyd_ref), 2μ_h));
            fraction = fthyd * bin.weight, symmetrize = TISymmetrize(ez)
        )
    end
    C_tiny = TensISO{3}(convert(T, 3TINY), convert(T, 2TINY))
    add_phase!(rve, :W, Ellipsoid(1.0), Dict(:C => C_tiny); fraction = ftw)
    add_phase!(rve, :AIR, Ellipsoid(1.0), Dict(:C => C_tiny); fraction = ftair)
    init = _hf_init(Val(start), wc, α_p, ω, sc_tol, T)
    return homogenize(rve, SelfConsistent(; init, sc_tol..., maxiters = 1000), :C; select_best = true)
end
Scales 2 and 3 — cement paste and mortar (Mori-Tanaka)
The converged foam is a TensTI{4}; best_fit_ti extracts its physical 5-parameter TI stiffness (Echoes does the same with tensor(C_hf.array, TI)) before the two Mori-Tanaka stages: clinker grains in the foam matrix (CP), then sand grains in the paste matrix (MO).
function build_cp(wc, α_p, C_hf)
    T = eltype(C_hf)
    rve = RVE(; T = T)
    add_phase!(rve, :CP, Ellipsoid(1.0), Dict(:C => C_hf); fraction = :rest)
    add_phase!(
        rve, :CLIN, Ellipsoid(1.0),
        Dict(:C => TensISO{3}(convert(T, 3K_clin), convert(T, 2μ_clin)));
        fraction = f_clin(wc, α_p)
    )
    return homogenize(rve, MoriTanaka(), :C)
end

function build_mo(wc, sc, C_cp)
    T = eltype(C_cp)
    rve = RVE(; T = T)
    add_phase!(rve, :CP, Ellipsoid(1.0), Dict(:C => C_cp); fraction = :rest)
    add_phase!(
        rve, :SAN, Ellipsoid(1.0),
        Dict(:C => TensISO{3}(convert(T, 3K_san), convert(T, 2μ_san)));
        fraction = fh_san(wc, sc)
    )
    return homogenize(rve, MoriTanaka(), :C)
end

# Full chain: scalar μ_b0 in, C_mo array out.
function multiscale_C_mo(wc, α_p, sc, μ_b0; N = NTHETA, ω = ω_aspect, kw...)
    C_hf = best_fit_ti(build_hf(wc, α_p, μ_b0; N = N, ω = ω, kw...), (0.0, 0.0, 1.0))
    C_cp = build_cp(wc, α_p, C_hf)
    C_mo = build_mo(wc, sc, C_cp)
    return Array(canonical_components(C_mo))
end
Strength criterion and the autodiff sensitivity
The criterion of Pichler and Hellmich (2011) bounds, in every family of hydrate needles, the quadratic average of the deviatoric stress,
The code below differentiates with respect to the stiffness parameter
The normalization of this page
This page keeps the normalization of Pichler and Hellmich (2011), with
is obtained by seeding Dual and reading the partial of the final array — one pass through the whole three-scale chain.
extract_kμ(arr) = k_mu(TensND.project(arr, Val(:ISO))[1])

function quasibrittle_strength(arr_C_mo, arr_dC, μh, f_θ)
    # `arr_C_mo` (value) and `arr_dC` (∂/∂μ) are 3×3×3×3 arrays; wrap them as
    # `Tens` and use intrinsic TensND algebra — the effective compliance is the
    # full inverse and the pull-back is one double contraction, no index loops.
    S = inv(Tens(arr_C_mo))
    M = S ⊡ Tens(arr_dC) ⊡ S
    return 1 / sqrt(abs(M[3, 3, 3, 3]) * 2μh^2 / f_θ)
end

function compute_point(wc, α_p; sc = 0.0, N = NTHETA, ω = ω_aspect, kw...)
    TagT = typeof(ForwardDiff.Tag(multiscale_C_mo, Float64))
    μ_dual = ForwardDiff.Dual{TagT}(float(μ_hyd_ref), 1.0)
    arr = multiscale_C_mo(wc, α_p, sc, μ_dual; N = N, ω = ω, kw...)
    arr_C = ForwardDiff.value.(arr)
    arr_dC = ForwardDiff.partials.(arr, 1)

    K_mo, μ_mo = extract_kμ(arr_C)
    E_mo, _ = E_nu(iso_stiffness(K_mo, μ_mo))
    f_θ = f_hyd(wc, α_p) * (1 - fh_san(wc, sc)) * polar_orientation_bins(N)[1].weight
    # criterion uses the iso parameter 2μ: d/d(2μ) = (1/2) d/dμ
    fc = quasibrittle_strength(arr_C, arr_dC ./ 2, μ_hyd_ref, f_θ)
    return (; K_mo, μ_mo, E_mo, fc)
end

r = compute_point(0.5, αmax(0.5) * (1 - 1e-12))
(k = round(r.K_mo, digits = 3), μ = round(r.μ_mo, digits = 3),
    E = round(r.E_mo, digits = 2), fc = round(r.fc, digits = 4))
(k = 12.27, μ = 8.055, E = 19.83, fc = 1.0913)Validating the angular discretization
The two starting points of the foam converge to the same fixed point, and the isotropic estimate of the first stage is the limit of the discrete families when the bins become infinitely many. Computing the point above both ways, and comparing the foam with that limit, checks the discretization into NTHETA bins:
let wc = 0.5, α_p = αmax(0.5) * (1 - 1e-12)
    r_iso = compute_point(wc, α_p)                      # two stages
    r_dir = compute_point(wc, α_p; start = :direct)     # one stage
    k_bins, μ_bins = k_mu(best_fit_iso(build_hf(wc, α_p, μ_hyd_ref)))
    k_iso, μ_iso = k_mu(build_hf_iso(wc, α_p))
    (E_gap = abs(r_iso.E_mo - r_dir.E_mo) / r_dir.E_mo,
        fc_gap = abs(r_iso.fc - r_dir.fc) / r_dir.fc,
        foam_vs_isotropic_limit = max(abs(k_bins - k_iso) / k_iso, abs(μ_bins - μ_iso) / μ_iso))
end
(E_gap = 1.6171659969935489e-9, fc_gap = 4.8729572473412335e-8, foam_vs_isotropic_limit = 2.5149345197495748e-9)The two routes agree to a few parts in
The rest of the chapter uses this single-pass sensitivity throughout. The following section is a pedagogical aside — it opens the black box to show what that one autodiff pass computes internally, and how it relates to the explicit chain rule of the original Echoes implementation. It is not needed to run the model.
Under the hood: the multi-scale chain rule made explicit
Two routes to the same derivative
The sensitivity
Direct (used above) — seed
as a ForwardDiff.Dualand let it propagate through the entire nested chainbuild_hf → build_cp → build_moin one evaluation. The chain rule happens automatically inside the dual-number arithmetic; you write no derivatives by hand.Explicit chain rule (this section, the Echoes approach) — differentiate each scale separately with respect to its input tensor, then multiply the per-scale Jacobians. Echoes assembles exactly this product with one
homogenize_derivativecall per transversely-isotropic (TI) parameter, per scale.
The explicit route is more work, but it makes the structure visible — and it reveals a key fact: because every intermediate stiffness is transversely isotropic (aligned needles in an isotropic matrix, then spherical clinker and sand), only five numbers — the TI parameters — flow between scales.
The bridge between the two views is the TI parameterization: extract the five parameters of a tensor with best_fit_ti — one of the symmetry projections re-exported from TensND — and rebuild a TensTI from five numbers.
const ez = (0.0, 0.0, 1.0)
ti5(C) = collect(TensND.get_data(best_fit_ti(C, ez)))     # tensor → 5 TI params
function rebuildTI(p)                                     # 5 params → TensTI
    T = eltype(p)
    return TensTI{4, T, 5}((p[1], p[2], p[3], p[4], p[5]),
        (T(ez[1]), T(ez[2]), T(ez[3])))
end
Now the three per-scale Jacobians, each a small ForwardDiff problem in the 5-parameter space rather than a pass through the whole model:
wc, α, sc = 0.5, αmax(0.5) * (1 - 1e-9), 0.0

# Scale 1 — how the five HF parameters respond to μ_hyd  (5-vector)
p_hf0 = ti5(build_hf(wc, α, μ_hyd_ref))
dHF_dμ = ForwardDiff.derivative(μ -> ti5(build_hf(wc, α, μ)), float(μ_hyd_ref))

# Scale 2 — how the CP parameters respond to the HF parameters  (5×5)
p_cp0 = ti5(build_cp(wc, α, rebuildTI(p_hf0)))
J_cp = ForwardDiff.jacobian(p -> ti5(build_cp(wc, α, rebuildTI(p))), p_hf0)

# Scale 3 — how the full mortar stiffness responds to the CP parameters  (81×5)
J_mo = ForwardDiff.jacobian(p -> vec(get_array(build_mo(wc, sc, rebuildTI(p)))), p_cp0)

(size_dHF_dμ = size(dHF_dμ), size_J_cp = size(J_cp), size_J_mo = size(J_mo))
(size_dHF_dμ = (5,), size_J_cp = (5, 5), size_J_mo = (81, 5))The chain rule is now literally a product of these Jacobians —
dCmo_chain = reshape(J_mo * (J_cp * dHF_dμ), 3, 3, 3, 3)

# same quantity, straight from one Dual pass through the whole chain
TagT = typeof(ForwardDiff.Tag(multiscale_C_mo, Float64))
μ_dual = ForwardDiff.Dual{TagT}(float(μ_hyd_ref), 1.0)
dCmo_direct = ForwardDiff.partials.(multiscale_C_mo(wc, α, sc, μ_dual), 1)

maxdiff = maximum(abs, dCmo_chain .- dCmo_direct)
println("max |chain rule − direct pass| = ", round(maxdiff, sigdigits = 3))
max |chain rule − direct pass| = 2.17e-19Same numbers, but the chain rule requires knowing the intermediate symmetry, choosing a consistent parameter ordering, and assembling the Jacobian product by hand — three opportunities for error that grow with the number of scales. The ForwardDiff pass differentiates whatever the model actually computes.
Results — strength and stiffness vs hydration degree
For pure cement paste (
wc_list = (0.25, 0.35, 0.5, 0.65)

pk = plot(; xlabel = "α", ylabel = "k_mortar (GPa)", legend = :topleft, framestyle = :box)
pμ = plot(; xlabel = "α", ylabel = "μ_mortar (GPa)", legend = false, framestyle = :box)
pfc = plot(; xlabel = "α", ylabel = "f_c / σ_ult", legend = false, framestyle = :box)

for wc in wc_list
    αs = range(0.05, αmax(wc) * (1 - 1e-9); length = 6)
    ks, μs, fcs, ak = Float64[], Float64[], Float64[], Float64[]
    for α in αs
        r = compute_point(wc, α)
        push!(ak, α); push!(ks, r.K_mo); push!(μs, r.μ_mo); push!(fcs, r.fc)
    end
    plot!(pk, ak, ks; label = "w/c=$wc", lw = 2)
    plot!(pμ, ak, μs; lw = 2)
    plot!(pfc, ak, fcs; lw = 2)
end

plot(pk, pμ, pfc; layout = (1, 3), left_margin = 8Plots.mm, bottom_margin = 8Plots.mm, size = (1200, 430),
    plot_title = "Cement paste (s/c = 0)")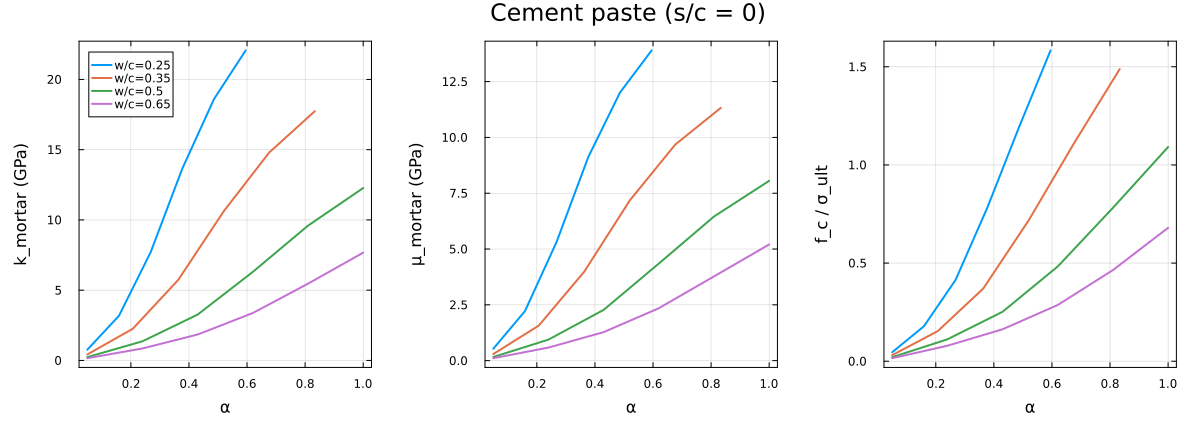
Effect of the sand content
Adding sand (increasing
psc = plot(; xlabel = "sand-to-cement ratio s/c", ylabel = "f_c / σ_ult",
    legend = :topright, framestyle = :box, size = (720, 440))
for wc in (0.35, 0.5, 0.65)
    scs = range(0.0, 5.0; length = 6)
    vals, kept = Float64[], Float64[]
    for sc in scs
        fc = compute_point(wc, αmax(wc) * (1 - 1e-9); sc = sc).fc
        push!(kept, sc); push!(vals, fc)
    end
    plot!(psc, kept, vals; label = "w/c=$wc", lw = 2, marker = :circle, ms = 3)
end
psc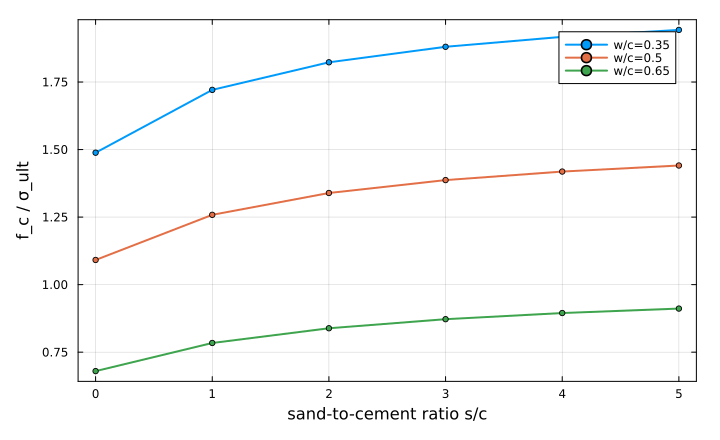
The absolute strength in MPa is recovered by multiplying by
The same chain, written declaratively
The model above is the explicit multiscale style: one function per scale, each handing its result to the next, and — because the whole chain has to be differentiated at once — a hand-rolled ForwardDiff.Tag seeded into μ_b0 and read back out of the final array.
The declarative style writes the same chain as a single object, a phase property being another cell plus a scheme. Here the last two scales are plain Mori-Tanaka stages with nothing in between, so they port directly:
function cp_mo_declarative(wc, sc, α_p, C_hf)
    T = eltype(C_hf)
    cp = RVE(; T = T)
    add_phase!(cp, :HF, Ellipsoid(1.0), Dict(:C => C_hf); fraction = :rest)
    add_phase!(cp, :CLIN, Ellipsoid(1.0),
        Dict(:C => TensISO{3}(convert(T, 3K_clin), convert(T, 2μ_clin)));
        fraction = f_clin(wc, α_p))

    mo = RVE(; T = T)
    add_phase!(mo, :CP, Ellipsoid(1.0), Dict(:C => Homogenized(cp, MoriTanaka())); fraction = :rest)
    add_phase!(mo, :SAN, Ellipsoid(1.0),
        Dict(:C => TensISO{3}(convert(T, 3K_san), convert(T, 2μ_san)));
        fraction = fh_san(wc, sc))
    return mo
end

let wc = 0.5, sc = 0.0, α_p = αmax(0.5) * (1 - 1e-12)
    C_hf = best_fit_ti(build_hf(wc, α_p, float(μ_hyd_ref)), (0.0, 0.0, 1.0))
    C_explicit = build_mo(wc, sc, build_cp(wc, α_p, C_hf))
    C_declarative = homogenize(cp_mo_declarative(wc, sc, α_p, C_hf), MoriTanaka(), :C)
    C_explicit == C_declarative
endtrueIdentical to the last bit — as it must be: the two styles differ in how the chain is written, not in what it computes.
Why the foam stage keeps its explicit form here
The seam between the hydrate foam and the cement paste is not a plain hand-off: the converged TensTI{4,T,8} is passed through best_fit_ti before the Mori-Tanaka stage, to match what Echoes does. A Homogenized resolves to whatever the inner scheme returns, so a post-processing step of that kind has to happen outside it.
That is the general rule stated in Multiscale models: the declarative style is for chains whose scales hand results straight to one another; a scale that needs a projection, a criterion or a change of variables in between keeps its explicit form. Both styles are first-class, and mixing them — as here, explicit at the foam seam and declarative afterwards — is normal.
What the declarative form would buy
Where a chain is fully declarative, the sensitivity plumbing disappears: the ForwardDiff.Tag seeding above is replaced by a lens naming the parameter, wherever it lives in the chain,
p = nested(:CP, :C, property(:HF, :C, :shear))    # μ of the foam, one scale down
gradient(mo, MoriTanaka(), [p]; indexer = C -> k_mu(C)[2])
and the inner cells are still solved exactly once per evaluation. The three-scale worked example is the multiscale tutorial, which writes one model both ways and checks that the derivatives agree with finite differences.
Where to go next
The lens written above, and the other ways of naming a parameter inside a nested chain, are described in Parameter lenses. The next application, The interfacial transition zone in concrete, carries the same paste one scale up, into a concrete whose aggregates are coated with a more porous paste.